Electronics, first
A B.Sc. in Electronics Engineering at Nantes Université. The robots came later; the circuits came first.
- B.Sc. Electronics Engineering
On the shelf: a book and a cap
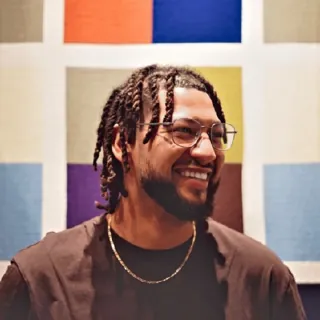 Erwin Lejeune Head of Robotics, SIRB.AI · Abu Dhabi
I lead robotics software teams across orchestration, navigation and fault management, and I stay hands-on in ROS 2, C++, Python and Go.
Scroll and the arm picks up one chapter at a time. Move your cursor and it follows you. Drag to look around.
A B.Sc. in Electronics Engineering at Nantes Université. The robots came later; the circuits came first.
On the shelf: a book and a cap
As an embedded software engineer, I built a SystemC/TLM virtual prototype of an STM32: TIM, I2C, CAN, GPIO and USART, wired into QEMU. Same years: an M.Sc. in Computer Engineering & Aeronautics at Ynov Bordeaux.
Treat time, memory and bandwidth as a budget. Test against a model of the hardware first.
On the shelf: a chip on its board
As a robotics assistant, I built full autonomy stacks from scratch with ROS and embedded systems, and won both maze-solving competitions: the mapped one and the unmapped one.
On the shelf: a maze cube
An M.Sc. in Control & Robotics, then research: I led four projects on multi-agent pathfinding, PDDL planning, real-time ROS control on Xenomai, and ROS 2 latency. Same period, remote for Hiventive: Go services with PostgreSQL and Docker.
On the shelf: a stack of papers
Founding robotics engineer on the team that delivered the first working in-store robot. I led navigation: planning, motion control, localization. When the CTO left, I also took on trolley detection, trained interns and a junior engineer, and ran the sprints.
A real store changes your priorities fast.
On the shelf: a shopping trolley
I designed swarm behaviours, including bird-inspired flocking published at IROS 2024, then grew and led a team of 9. We cut onboard CPU by 74% and bandwidth by 52%, and worked with Caltech on their M4 robot. Demos led to USD 3M, then over USD 10M, in contracts.
On the shelf: a drone, and the arm lets it fly
I founded Unchained Labs: local-first AI agents that run on a company's own models, data and infrastructure. Kymatics, our graph-based orchestrator, turns a spoken intent into a queue of build jobs.
On the shelf: a microphone and its sound wave
Head of Robotics, founding team. I designed the robotics architecture and a self-healing autonomy layer: fault and state recording across the swarm, agents that detect and recover from failures, ML-based mission scoring before launch. We went from prototype to public launch at UMEX 2026.
سرب sirb is Arabic for a flock, or a swarm.
On the shelf: a swarm, in formation
Notes
AI lets a team ship more without lowering the bar, as long as every change goes through the same cell, whoever or whatever wrote it.
Off the clock
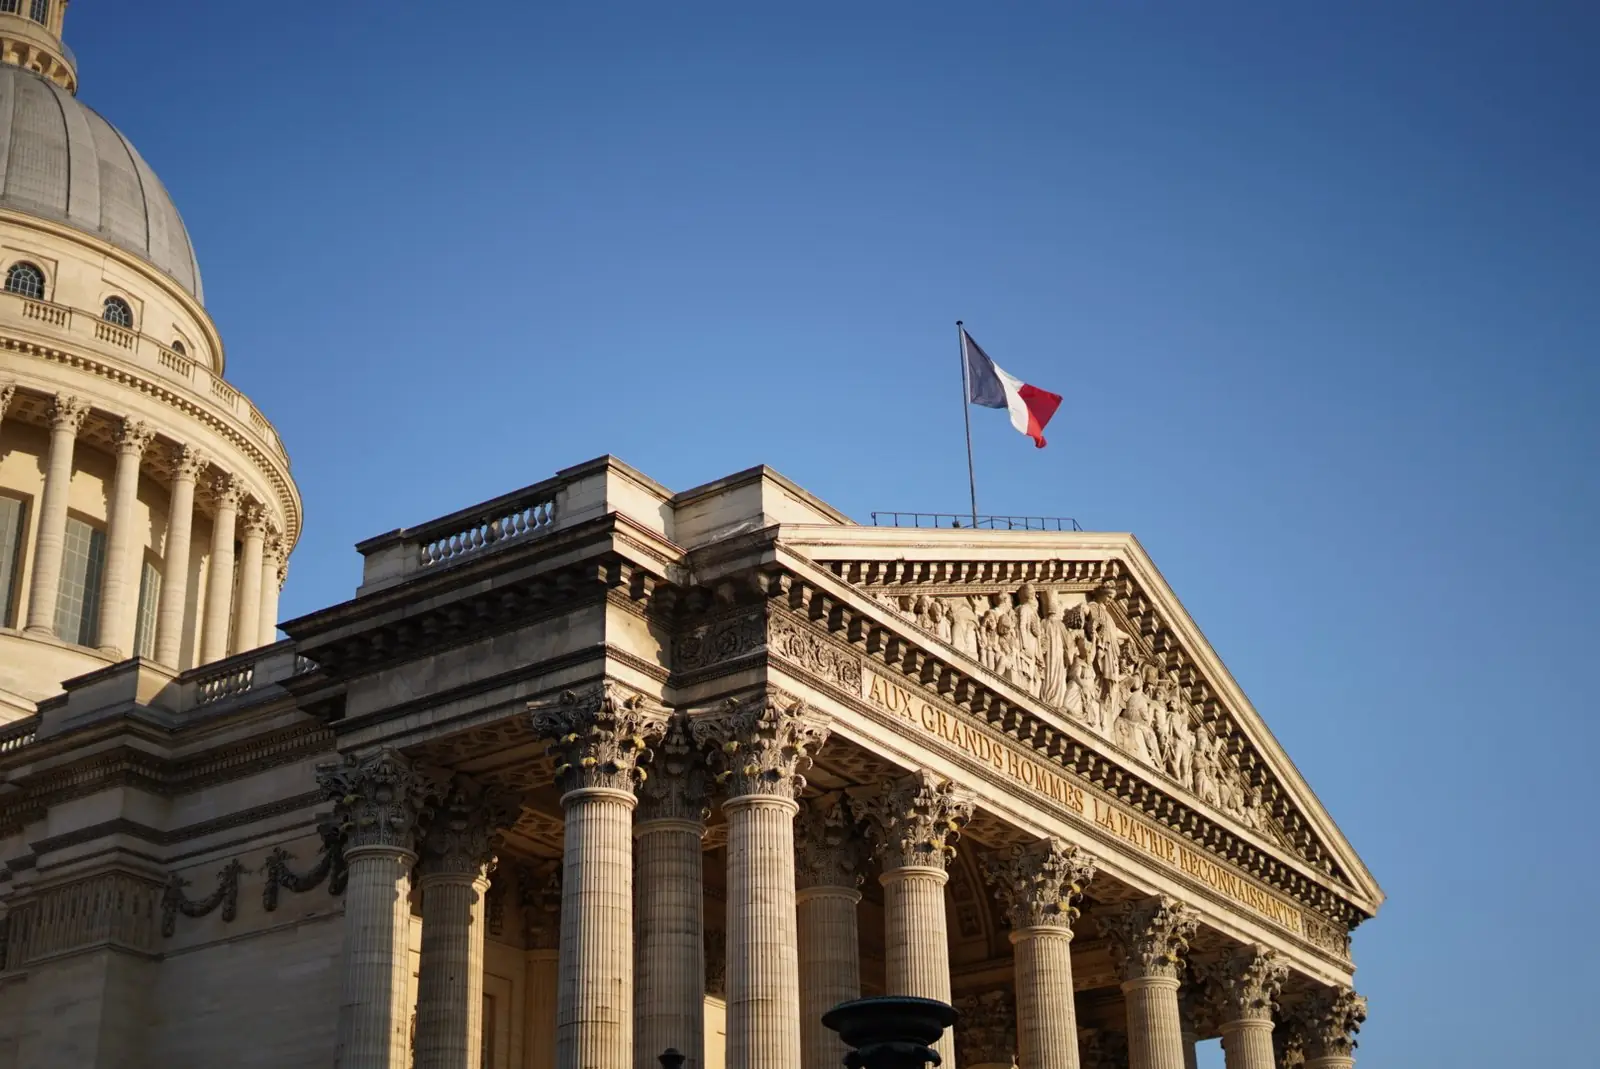
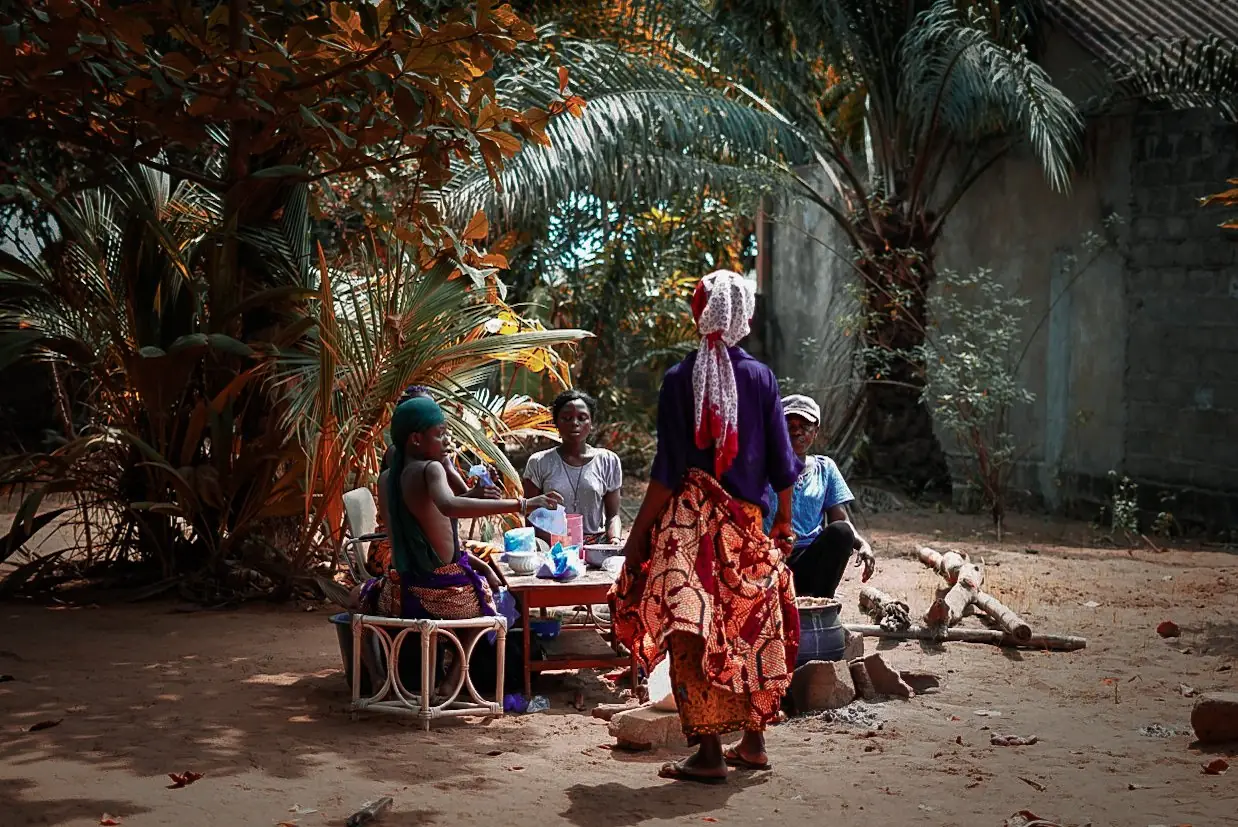
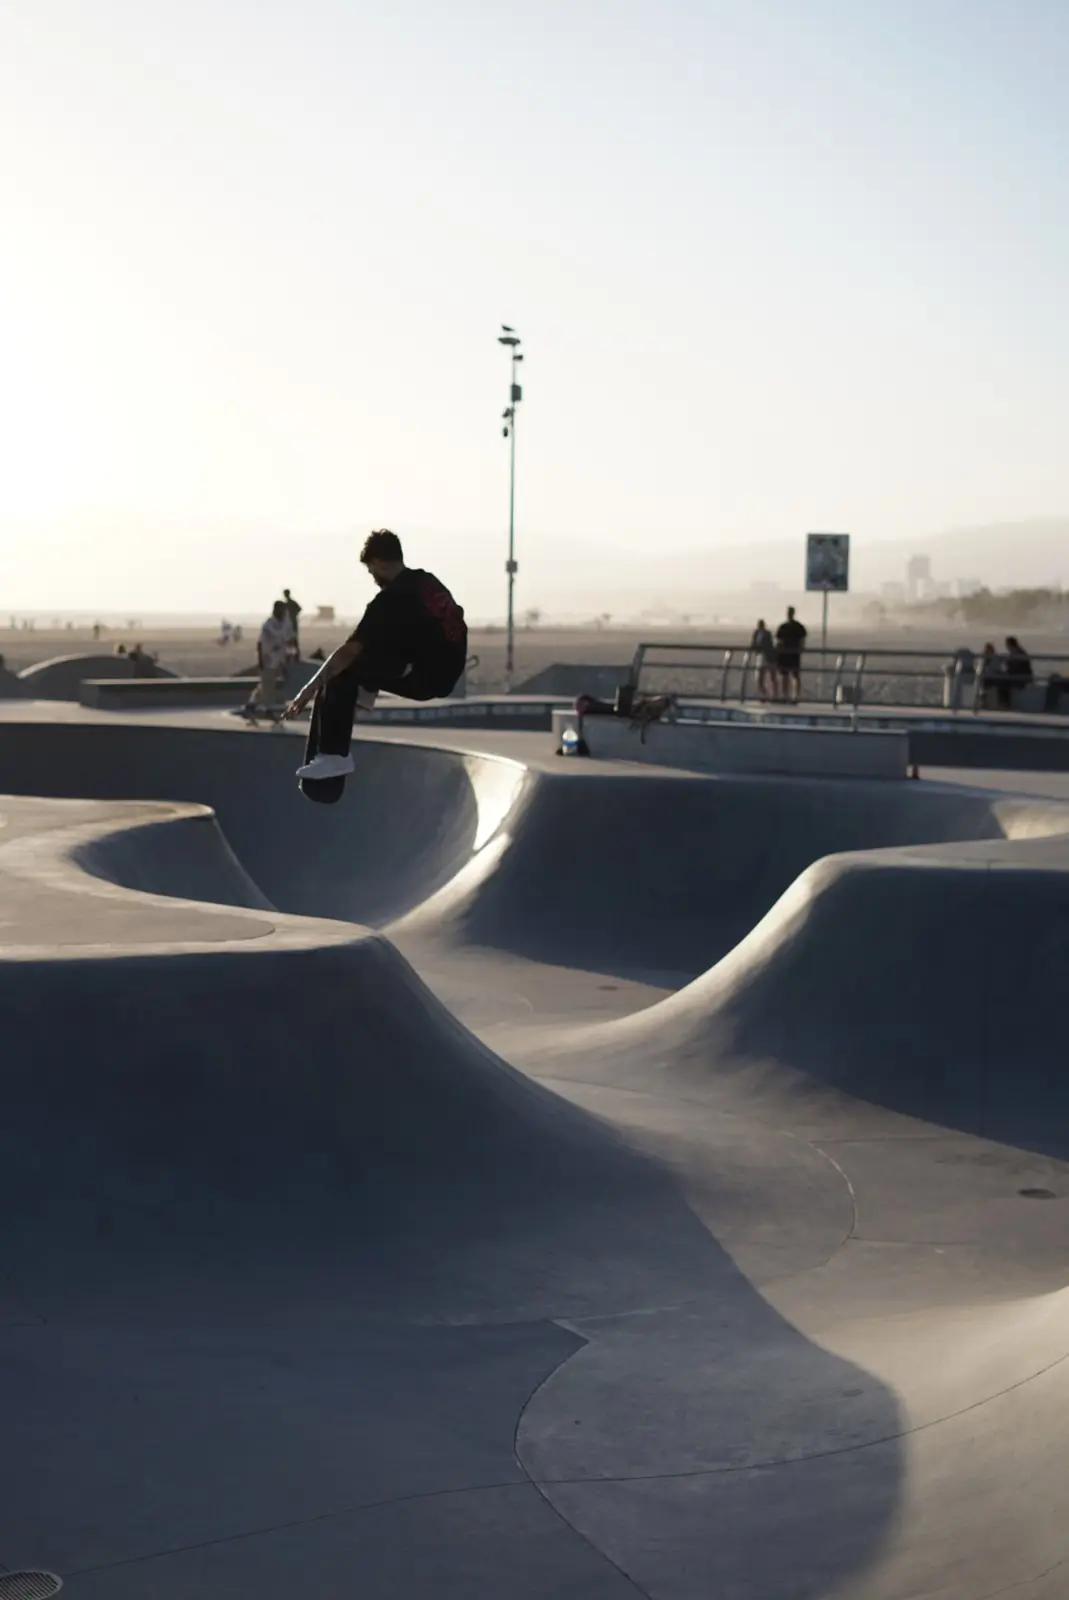
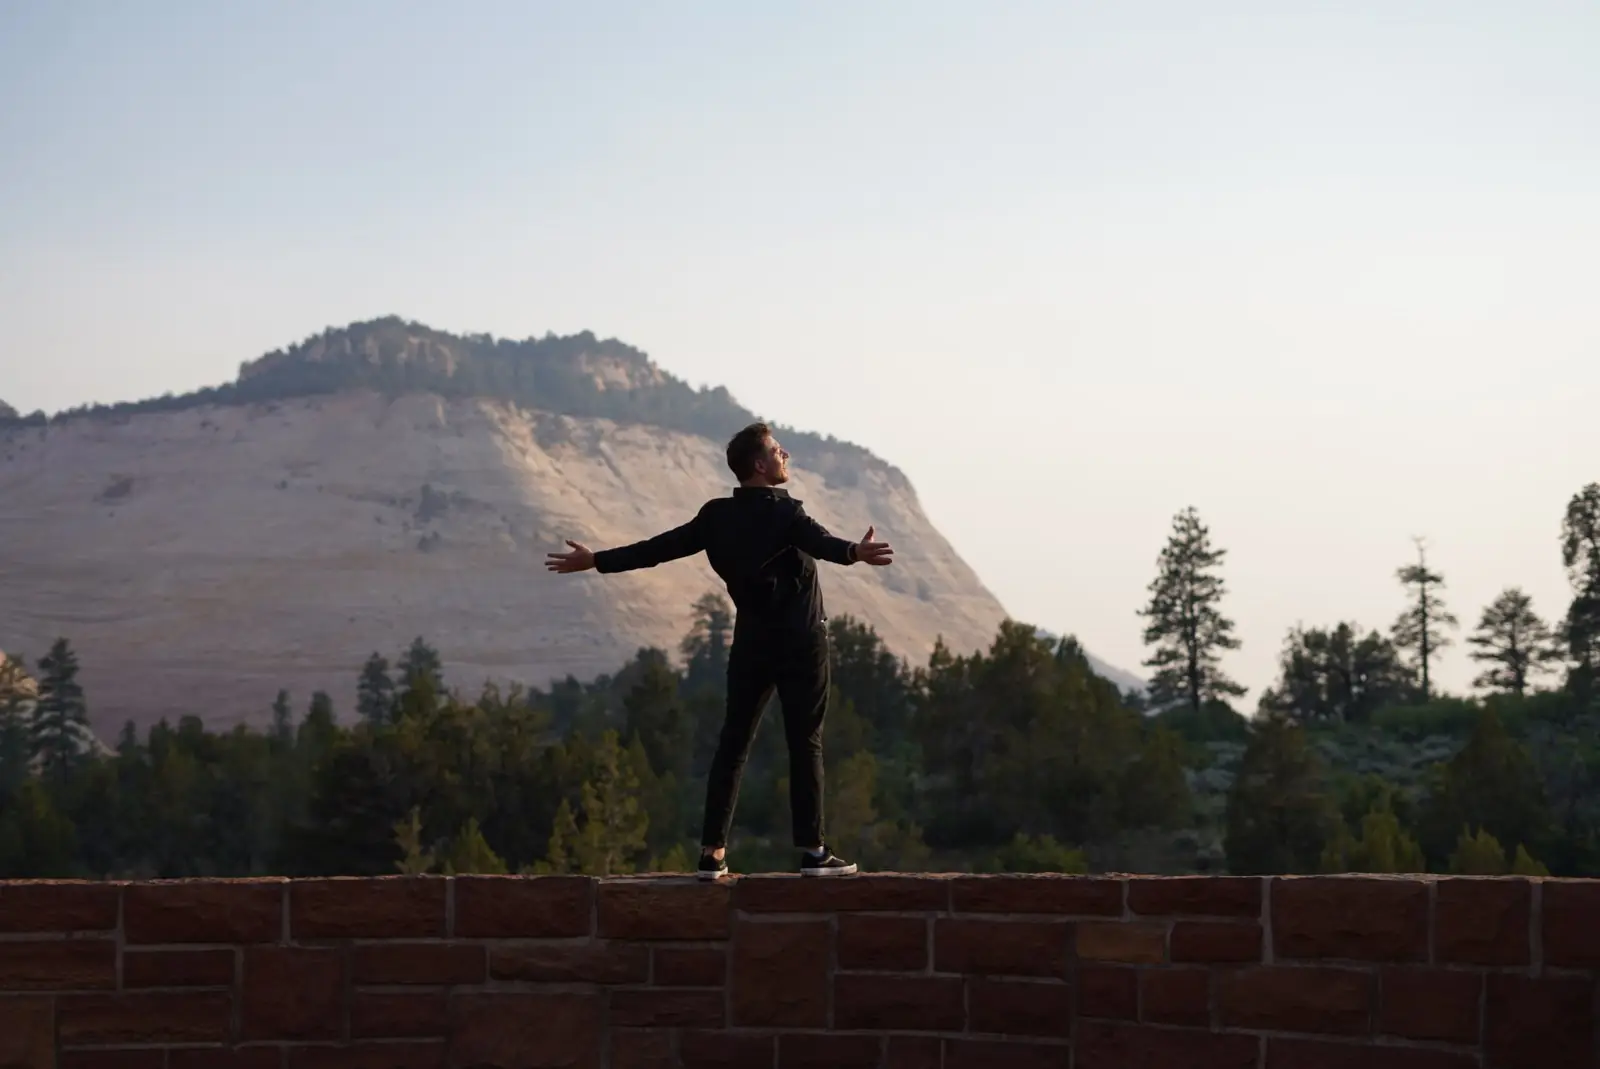
And Clanker Labs, my self-hosted home with an agent running it. The photos are mine; 2023 took me through California and the US West, Paris, Togo, Tokyo, the Maldives and Dubai.
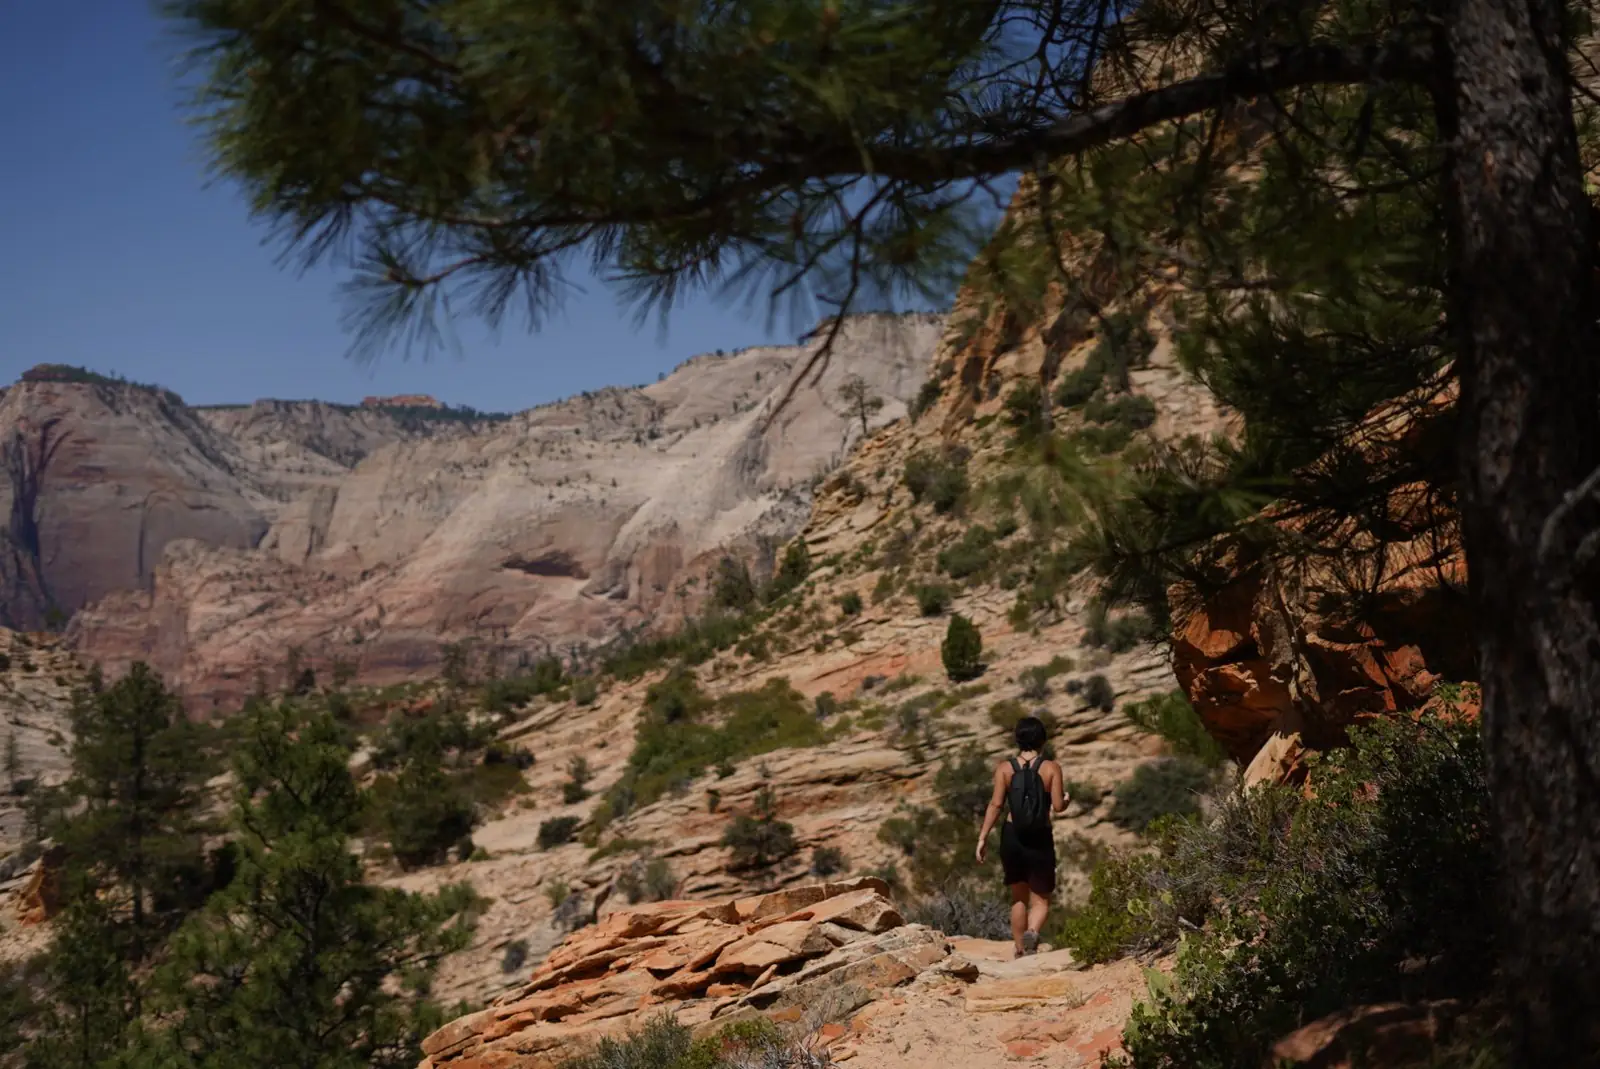
The shelf is full
A question about multi-agent planning, swarms, an open-source idea, or just hi.